


Updated October 2026: This article has been corrected. WebODM is a separate project from OpenDroneMap and runs its own engine, ODX, and WebODM Lightning runs a different engine, LGT. An earlier version said WebODM’s quality reporting was minimal and that checkpoints had to be handled by hand. In fact, ODX produces a quality report with a separate checkpoint table. The WebODM section and the decision framework have been updated to match.
Four drone mapping software platforms. One is the industry accuracy standard. One has the best 3D mesh quality on the market. One is free. One processes a 1,000-image dataset faster than the others finish initializing.
Choosing the wrong one is expensive — in money, in time, or in a quality report that doesn’t hold up when a client pushes back.
This comparison covers what each platform actually does well, where each one breaks down, and which belongs in your workflow depending on what you’re delivering.
The Short Answer


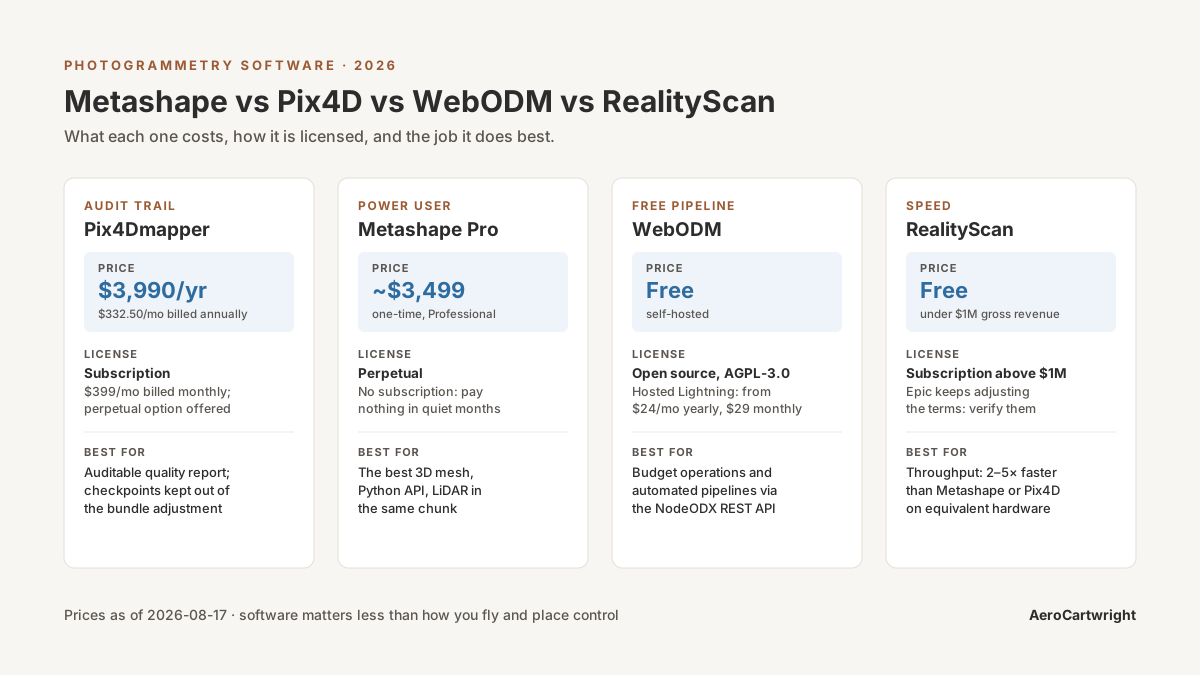
If you’re delivering to engineers, agencies, or clients who require auditable accuracy documentation: Pix4Dmapper or Metashape.
If processing time is your production bottleneck: RealityScan (the desktop app Epic sold as RealityCapture until June 2025).
If you need Python automation or the best 3D mesh available: Metashape.
If you’re budget-constrained, building a server pipeline, or learning the workflow: WebODM (note: WebODM split from OpenDroneMap in April 2026 — it’s now a separate project running its own ODX engine).
Now for the detail.
Pix4Dmapper: The Audit Trail Platform
Pix4Dmapper isn’t the fastest. It isn’t the cheapest. It’s the benchmark — because of what it produces after processing: a quality report detailed enough to defend your results to a client, an engineer, or a regulatory agency.
 Image credit: Pix4D. Official support documentation. Used for editorial comparison.
That quality report matters more than most operators realize. A client disputes your accuracy. A regulator asks for documentation. Something looks off and you need to diagnose it fast. The Pix4D report gives you the full evidence chain — reprojection error, GCP residuals by axis, checkpoint residuals by axis, overlap map with yellow and red zones flagged, camera optimization statistics, image geolocation deviation. Everything you need to answer the question before it becomes a problem.
The GCP and checkpoint workflow is the clearest of any platform here. Import coordinates, mark points on images, designate each as GCP or checkpoint, process. The software enforces the separation — checkpoints never touch the bundle adjustment. What shows up in the final report as checkpoint RMSE is independent validation, not self-reported fit.
Other platforms blur the GCP/checkpoint line if you’re not deliberate about it. Pix4D builds the separation into the workflow so you can’t accidentally corrupt your validation. That matters more than people think.
Where Pix4Dmapper falls short:
The UI hasn’t kept pace with the processing engine — it’s dated compared to Metashape. Speed is moderate — competitive with Metashape, nowhere near RealityScan. And if you’re not flying year-round, the subscription model is painful. You’re paying monthly whether you’re processing or not. Pix4D no longer advertises a perpetual license for Pix4Dmapper; its pricing page lists subscriptions only ($399/month, or $332.50/month billed annually at $3,990/year), so a seasonal load is where Metashape’s one-time license pulls ahead.
The product line has also gotten confusing. Pix4Dmatic is Pix4D’s newer platform — large-scale, cloud and desktop, subscription-only. The relationship between the two is unclear to new buyers, and Pix4Dmatic’s quality reports aren’t as mature. For survey-grade deliverables, Pix4Dmapper is still the right choice. Not Pix4Dmatic. (For the 2026 restructure — Pix4Dsurvey folded in, new Standard/Analyst/Pro tiers — see the Pix4Dmatic 2.0 deep dive.)
Who should use it: Drone surveyors delivering to engineers, DOT, FEMA, or any client requiring documented accuracy with an auditable paper trail. Anyone whose business depends on being able to defend their checkpoint RMSE with a PDF.
Agisoft Metashape Professional: The Power User’s Platform
Metashape fits best when the deliverable is a 3D model, when workflow automation matters, or when a perpetual license makes more sense than an ongoing subscription.
The perpetual license is the reason. Process heavy for a few months, go quiet, pay nothing during the quiet months. If your project load is seasonal or project-based, that’s real money back in your pocket.
3D mesh quality: Metashape produces the best photogrammetric mesh of any platform in this comparison. Architectural documentation, heritage recording, structural inspection — anything where the deliverable is a model rather than an orthomosaic and DEM, Metashape wins. Denser point cloud, better complex-geometry handling, cleaner texture mapping.
Python scripting: Metashape’s underrated differentiator for high-volume shops. The Python API exposes the full pipeline — chunk creation, camera import, marker placement, alignment, dense cloud, export. You can script an entire project from raw imagery to delivered GeoTIFF and LAZ without touching the GUI.
# Automate alignment and dense cloud in Metashape
import Metashape
doc = Metashape.Document()
doc.open("project.psx")
chunk = doc.chunks[0]
chunk.matchPhotos(downscale=1, generic_preselection=True)
chunk.alignCameras()
chunk.buildDepthMaps(downscale=4, filter_mode=Metashape.MildFiltering)
chunk.buildPointCloud()
doc.save()
Process multiple projects per week and that automation compounds into serious time savings over a year.
Metashape 2.x: The 2.x series added AI-based point cloud classification — ground, vegetation, building detection — that holds up well against standalone classification tools. You can now ingest and process LiDAR data in the same chunk as photogrammetry data — useful if you’re running a hybrid payload. Depth map generation got a significant upgrade.
Where Metashape falls short:
The quality report is good — not as detailed as Pix4D’s. GCP residuals are reported by axis, but the checkpoint workflow requires deliberate setup. You must manually designate markers as checkpoints, and it’s easy to accidentally include checkpoints in the bundle adjustment if you’re not paying attention. That’s a real risk on deadline.
The processing pipeline is also more manual than Pix4D’s. Pix4D runs front to back with one click. Metashape makes you step through alignment, depth maps, dense cloud, mesh, orthomosaic, and DEM as separate operations. Experienced users like that control. New users find it confusing.
The learning curve is steeper than any platform here. Knowing which processing quality setting — “Highest,” “High,” “Medium” — to use at which stage, and why, takes time. Pix4D largely abstracts that away.
Who should use it: Operators who need 3D model quality, Python automation, or a perpetual license. GIS analysts processing multiple project types. Anyone doing architectural, heritage, or structural work where mesh quality outweighs quality report format.
WebODM: The Free Pipeline
WebODM is the front-end. The processing engine and API live underneath. Since the April 2026 split, WebODM has been a separate project from OpenDroneMap and runs its own forks of the stack: ODX, NodeODX, and ClusterODX. OpenDroneMap continues maintaining ODM, NodeODM, and ClusterODM. ODX is a separate engine (WebODM describes it as faster than ODM), and the two stacks aren’t guaranteed to be compatible. Full breakdown in the WebODM, ODX & OpenDroneMap ecosystem guide.
Your entry points:
- ODX: The engine on its own — command-line, with a native Windows installer or Docker on any OS. Free. You need to be comfortable with a terminal.
- WebODM: Browser-based GUI wrapping the engine. Self-hosted and free: a native installer on Windows, an installer on macOS that sets up Docker for you, or Docker on Linux.
- WebODM Lightning: The hosted service, operated by UAV4GEO — lowest friction, nothing to install or manage. It processes on LGT, a separate engine only available on Lightning. Pay As You Go, or plans from $24/month billed yearly ($29 billed monthly). You can also add Lightning as a processing node inside a self-hosted WebODM.
 Image credit: WebODM. Open source (AGPL-3.0). Used for editorial comparison.
Accuracy: The open-source pipeline surprises people who assume free means worse. Published research consistently shows ODM — the engine ODX was forked from — producing checkpoint RMSE competitive with commercial platforms when you configure GCPs properly. On controlled datasets with adequate imagery, sub-5 cm horizontal and sub-8 cm vertical from ODM is achievable — in the same range as Pix4D and Metashape on identical inputs.
The caveat: the open-source pipeline is less forgiving of marginal data. Low overlap, inconsistent exposure, challenging terrain — commercial platforms have more robust fallback processing.
Quality reporting is built in. ODX produces a quality report with an overlap diagram, average reprojection error, camera calibration (initial vs optimized parameters), and GCP error statistics. Give a point a CHK- prefix in the GCP file and it becomes a checkpoint: it’s excluded from the adjustment, and the report lists each checkpoint’s X, Y, and Z error in a separate Checkpoints table. The PDF doesn’t print a checkpoint RMSE summary, but computing one from that table is a small step. Pix4D’s report is longer and is the long-standing industry reference; WebODM’s covers the core audit trail.
Where WebODM falls short:
GCP workflow is less polished. WebODM takes a plain-text GCP file (a coordinate-system header, then X Y Z, pixel position, and image name for each observation) and includes a built-in interface for marking points on images; GCP Editor Pro is a commercial option. It works, but it isn’t as integrated as Pix4D’s click-to-assign workflow.
Large datasets need serious hardware. WebODM’s documentation gives conservative estimates of 64 GB of RAM for 1,500 images and 256 GB for 5,000 images, so a project that Metashape or Pix4D handles routinely may need RAM tuning, split-merge, or a bigger machine.
The server deployment case: WebODM’s real professional strength is server-side pipeline integration. NodeODX exposes a REST API — you plug the engine into a custom data workflow for automated ingest, processing, and delivery at a fraction of what commercial platforms charge for equivalent access. Corridor surveys, ag monitoring, infrastructure inspection — if you’re running large volumes of standardized mapping, this on dedicated processing hardware delivers real cost savings without sacrificing accuracy.
Who should use it: Budget-conscious operators. Teams building automated processing pipelines. Anyone learning the photogrammetric pipeline before committing to a commercial license.
RealityScan (Formerly RealityCapture): The Speed Platform
RealityScan is the outlier. If you knew it as RealityCapture, it’s the same desktop application: with the 2.0 release in June 2025, Epic Games renamed RealityCapture to RealityScan, the name it already used for its mobile scanning app (Epic’s RealityScan 2.0 announcement).
Epic acquired it in 2021 and restructured the pricing multiple times. The pay-per-input model was discontinued in April 2024, when the software became free for companies under $1 million in revenue. With RealityScan 2.0, Epic states it is free for students, educators, and individuals and companies with annual gross revenue below $1 million USD; above that, a subscription is required. Verify current terms on the RealityScan site; Epic keeps adjusting the model.
That shift opened RealityScan to a much wider range of operators. The processing engine didn’t change — it was already the fastest photogrammetry platform available by a wide margin. It still is.
Processing speed: RealityScan processes 2-5x faster than Metashape or Pix4D on equivalent hardware. That number isn’t marketing — it holds in practice on real datasets. A processing job that runs overnight in Metashape finishes in a few hours in RealityScan. On large surveys — 2,000+ images, multi-battery missions across hundreds of acres — the difference is operational. You’re either sleeping while it processes or reviewing results before lunch.
 Image credit: Capturing Reality / Epic Games. Official promotional image. Used for editorial comparison.
The speed comes from a different internal architecture. RealityScan uses graph-based registration for sparse reconstruction — a fundamentally different approach than the SfM pipeline in Pix4D and Metashape. It parallelizes more efficiently across GPU cores and uses GPU compute more aggressively. A workstation with a high-end GPU sees proportionally larger gains in RealityScan than in any competing platform. Better GPU, bigger gap.
3D reconstruction quality: On complex geometry — buildings, structures, terrain with significant vertical relief — RealityScan’s mesh quality is competitive with Metashape. Heritage documentation professionals favor it for exactly this reason.
Where RealityScan falls short for survey work:
The GCP workflow exists — less polished than Pix4D’s or Metashape’s. You import GCPs, mark them on images, constrain the reconstruction. Checkpoints are handled in the software: a control point set to the Ground Test type is excluded from the scene optimization, and its deviation from the surveyed position is shown in the alignment report (Epic’s Control Points help). Accuracy reporting beyond that is minimal. No equivalent to Pix4D’s quality report PDF.
 Image credit: Capturing Reality / Epic Games. Official help documentation. Used for editorial comparison.
GIS output is functional — GeoTIFF orthomosaics, LAS/LAZ point clouds, DEMs — but CRS management and coordinate system handling require more configuration than Pix4D or Metashape for standard survey workflows. You can make it work. It takes longer to set up correctly.
RealityScan is also less integrated with the GIS ecosystem. It has no in-app Python API like Metashape’s; automation runs through its command-line interface, which chains processing steps as command-line flags, and a REST/gRPC Remote Command Plugin added in 2.1. The workflow is oriented toward 3D output, not geospatial deliverables.
Who should use it: High-volume operators where processing time is the primary constraint. Teams doing BIM integration, heritage documentation, or 3D visualization where mesh quality matters more than GIS deliverables. Anyone previously priced out of commercial photogrammetry who needs fast, capable processing without a subscription.
RealityScan vs Agisoft Metashape: Head-to-Head
RealityScan and Agisoft Metashape are the two premium non-Pix4D engines, and operators comparing them are usually choosing a 3D-quality workhorse rather than a survey-report platform. Here is how the two separate.
Speed: RealityScan wins decisively — it processes roughly 2–5× faster than Metashape on equivalent hardware, and the gap widens with a higher-end GPU. A job that runs overnight in Metashape can finish in a few hours in RealityScan.
3D mesh quality: Close, with Metashape holding a slight edge on complex geometry, dense-cloud density, and texture mapping. Both comfortably out-resolve WebODM and Pix4D for pure model work.
Pricing: RealityScan is free for companies under $1M in annual gross revenue, with a paid subscription above that threshold ($1,250 per seat per year on Epic’s licensing page, checked 2026-11-03). Metashape is a one-time perpetual license — roughly $3,499 for Professional — with no subscription. Seasonal or project-based shops often prefer the perpetual model; high-volume shops lean on RealityScan’s free tier.
Automation & GIS: Metashape wins here. Its Python API scripts the full pipeline end to end, it ingests LiDAR in the same chunk as photogrammetry data, and its coordinate-system handling is more survey-friendly. RealityScan has no Python API of its own — you automate it through command-line flags, batch files or the REST/gRPC Remote Command Plugin instead — and it needs more manual CRS configuration for standard survey workflows.
GCP & accuracy reporting: A wash, and a weakness for both. Both can hold checkpoints out of the adjustment (Metashape markers designated as check points, RealityScan Ground Test points), but neither matches Pix4D’s auditable quality report. If you need defensible checkpoint RMSE documentation, the Pix4Dmapper section above is still the answer.
Bottom line: Choose RealityScan when processing speed or a zero-cost entry is the constraint; choose Metashape when you need Python scripting, LiDAR fusion, a perpetual license, or the best mesh for heritage and architectural work.

Accuracy: What the Research Shows
Here’s what surprises most practitioners: published research comparing these platforms shows more consistency across software than the marketing suggests. On well-executed flights with solid GCPs, all four platforms produce checkpoint RMSE within a similar range.
Software matters less than flight geometry: Agüera-Vega et al. (2017), writing in Measurement, found that GCP count and distribution had a significant effect on accuracy — increasing from 4 to 20 GCPs reduced checkpoint RMSE substantially. The study used Pix4D on controlled agricultural datasets, and the conclusion is consistent across platforms: how you distribute ground control matters more than which software runs the bundle adjustment.
Oblique imagery effect dominates everything: Nesbit & Hugenholtz (2019) in Remote Sensing found that adding oblique images to nadir blocks “consistently improves spatial accuracy and precision” over high-relief badlands terrain — higher overlap and 20–35° camera angles improved precision and accuracy by nearly 50% over nadir-only blocks. Every scenario was processed in Pix4Dmapper alone, so the study isolates flight geometry, not software. Same lesson, different methodology: the fix for vertical accuracy is in the mission planning, not the software license.
Doming is geometric, not software-specific: James & Robson (2014) — the foundational paper on systematic error in SfM photogrammetry, published in Earth Surface Processes and Landforms — showed in simulations that near-parallel nadir imagery combined with an inaccurate camera model produces dome-shaped DEM deformation (about 0.2 m over 100 m in their UAV-like case with no ground control), and that adding oblique images cut it by one to two orders of magnitude. They didn’t test any commercial packages. The error source is image geometry and the camera model, not a particular platform. Platforms differ in how visibly they report it (Pix4D flags doming explicitly in the quality report; others don’t) — not in whether it occurs.
ODM holds up on controlled datasets: Studies evaluating ODM (the engine ODX was forked from) against commercial platforms — including work published in ISPRS Annals of the Photogrammetry, Remote Sensing and Spatial Information Sciences — found checkpoint RMSE from ODM within 2–3 cm of Pix4D and Metashape on well-configured datasets with proper GCPs. The gap grows on complex terrain without adequate control.
The takeaway is simple: software choice matters less than how you fly and how you place control. A well-executed mission with proper GCPs produces accurate deliverables in any of these platforms. A bad flight produces bad deliverables regardless of what software license is on the machine.
The Decision Framework
You need auditable accuracy documentation:
Pix4Dmapper. Its quality report is the long-standing industry reference for defensibility. Checkpoint RMSE by axis, independent validation separated from GCPs, overlap map, camera optimization — it’s all there. If your client, engineer, or agency expects the industry-standard report, Pix4D is the call.
You need 3D model quality or workflow automation:
Metashape Professional. Perpetual license, Python API, best mesh output. If you’re scripting batch processing or delivering 3D models alongside orthomosaics, Metashape’s depth wins.
Processing speed is the bottleneck:
RealityScan. If your production constraint is time-in-queue, RealityScan’s speed advantage is real. It compounds across every project.
You’re building a budget operation or automated pipeline:
WebODM. Competitive accuracy when properly configured, with a built-in quality report and checkpoint table. The tradeoff is technical overhead.
What actually works in practice: Many professional operations run two platforms. Metashape for 3D model work and internal processing. Pix4Dmapper for projects requiring delivered accuracy documentation. WebODM for routine and pipeline processing. These tools aren’t mutually exclusive — and the combination often makes more financial sense than a single expensive subscription.
For how to read the accuracy numbers that come out of these platforms — checkpoint RMSE, GCP residuals, reprojection error, what each one actually means — that breakdown is here.
References
Research and standards cited in this article.
- Agüera-Vega, F., Carvajal-Ramírez, F., & Martínez-Carricondo, P. (2017). Assessment of photogrammetric mapping accuracy based on variation ground control points number using unmanned aerial vehicle. Measurement, 98, 221–227. doi:10.1016/j.measurement.2016.12.002
- James, M. R., & Robson, S. (2014). Mitigating systematic error in topographic models derived from UAV and ground-based image networks. Earth Surface Processes and Landforms, 39(10), 1413–1420. doi:10.1002/esp.3609
- Nesbit, P. R., & Hugenholtz, C. H. (2019). Enhancing UAV–SfM 3D model accuracy in high-relief landscapes by incorporating oblique images. Remote Sensing, 11(3), 239. doi:10.3390/rs11030239